Abstract
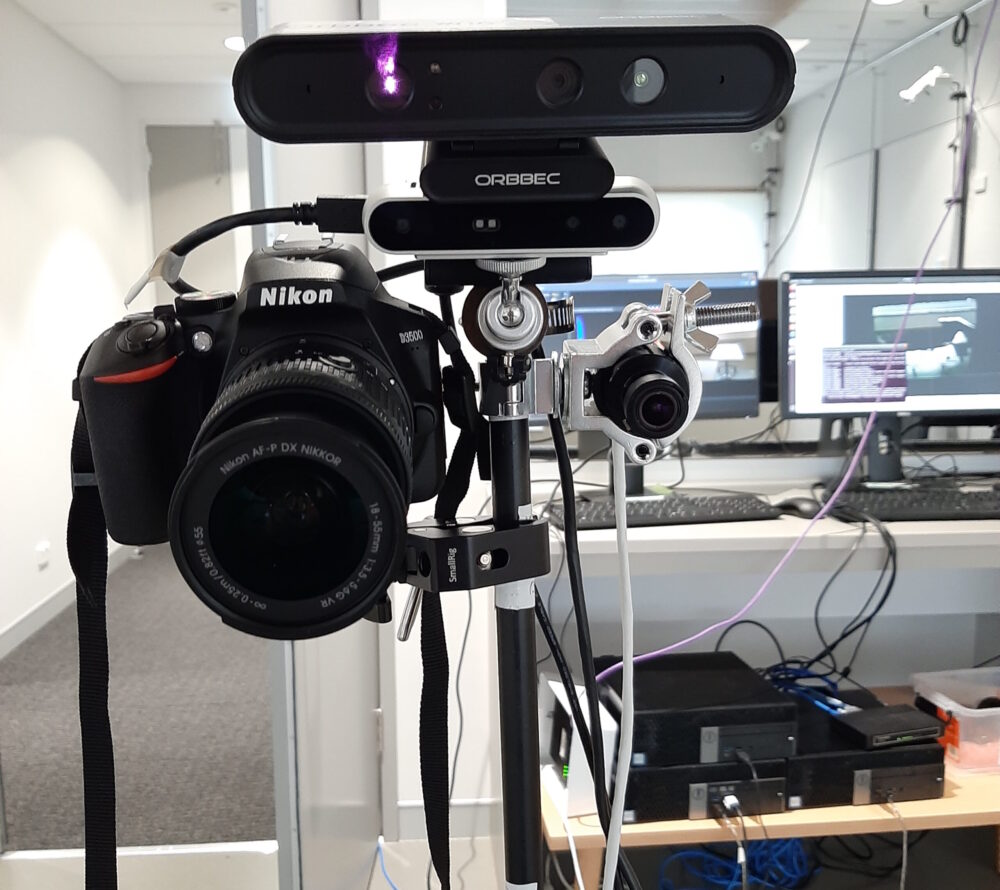
The Multiple Sensors Multi-instance (MSMI) Dataset represents a comprehensive collection of multi-sensor data designed to support research in robotics and machine learning applications. This dataset addresses the growing need for diverse, multi-modal data sources in the development of robust robotic systems capable of operating in complex, real-world environments.
The MSMI dataset incorporates data from multiple sensor modalities, including visual, auditory, tactile, and environmental sensors, captured across various scenarios and conditions. This multi-instance approach provides researchers with rich, diverse data that reflects the complexity of real-world robotic applications, enabling the development of more robust and adaptable systems.
The dataset is designed to support various research applications, including sensor fusion, multi-modal learning, robotic perception, and autonomous system development. By providing access to high-quality, multi-sensor data, this resource aims to accelerate research progress in these critical areas of robotics and artificial intelligence.